Lorenz-84 System
Model
The following is the governing equation of the Lorenz-84 system.
$$ \begin{align*} \dot{x} =& - a x - y^2 - z^2 + a F \\ \dot{y} =& - y + x y - b x z + G \\ \dot{z} =& - z + b x y + x z \end{align*} $$
Parameters
- $a = 0.25$
- $b = 4$
- $F= 5$, $G= 1$: These mainly serve as the bifurcation parameters.
Explanation
Along with Lorenz-63 and Lorenz-96, this is an attractor bearing Lorenz’s name. Compared with Lorenz-96, which retains only its form in a high-dimensional space, Lorenz-84 is said to have real meaning, like the circulation of the atmosphere.
As an example, it is an extremely important system because it exhibits bifurcations incomparably richer than those of other systems.
Attractor
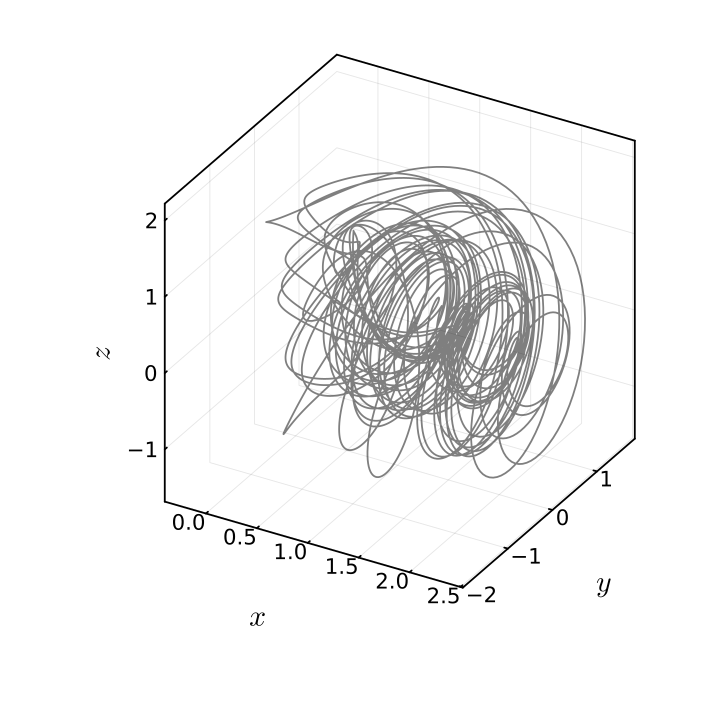
Looking at the strange attractor, it is so complicated that it is hard to describe what it looks like.
Bifurcation
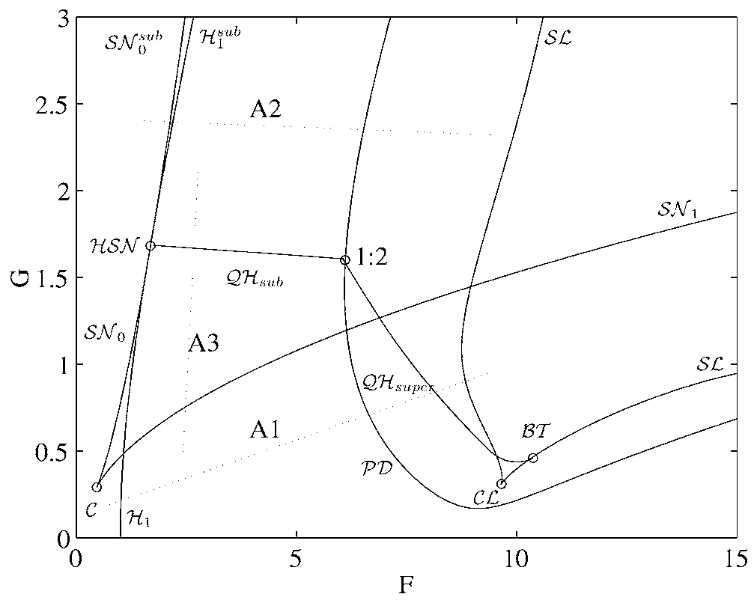
Usually, when dealing with Lorenz-84, rather than looking at only one parameter, one looks at $F, G$ simultaneously and treats codimension-2, and its bifurcation diagram is as shown above.
- $H$: A Hopf bifurcation occurs.
- $SN$: A saddle-node bifurcation occurs.
- $PD$: Period doubling occurs.
- $C$, $CL$: A cusp bifurcation occurs.
- $BT$: A Bogdanov–Takens bifurcation occurs.
Code
using DataFrames, DifferentialEquations, OrdinaryDiffEqLowOrderRK

function factory_lorenz84(FG; ic = [1.0, 1.0, 1.0], saveat = 0:1e-2:100)
    F, G = FG
    a, b = (0.25, 4)
    function sys(du, u, p, t)
        x, y, z = u
        F, G = p

        du[1] = -a*x - y^2 - z^2 + a*F
        du[2] = -y + x*y - b*x*z + G
        du[3] = -z + b*x*y + x*z
        return du
    end
    sol = solve(ODEProblem(sys, ic, (0, last(saveat)), [F, G]), RK4(), dt = saveat.step.hi, adaptive=false, maxiters = Inf)
    dsol = [sol.k[2][1] stack([solk[2] for solk in sol.k[2:end]])]
    matrix = [sol.t sol[:, :]' dsol']
    return matrix[sol.t .≥ first(saveat), :][1:end-1, :]
end
factory_lorenz84(T::Type, args...; kargs...) =
DataFrame(factory_lorenz84(args...; kargs...), ["t", "x", "y", "z", "dx", "dy", "dz"])

sol = factory_lorenz84(DataFrame, [5, 1]; ic = [1, 1, 1], saveat = 900:1e-2:1000)
plot(sol.x, sol.y, sol.z, alpha = .5, color = :black, xlabel = L"x", ylabel = L"y", zlabel = L"z", size = [400, 400])